
Isaac GR00T Faster Humanoid Development
NVIDIA Isaac™ GR00T gives developers an open, end-to-end software stack with reference designs, development workflows, and foundation models to accelerate the development and deployment of general-purpose robot policies.
GR00T Reference Platform
A full-stack platform spanning robot hardware, onboard compute and system software, integrated with GR00T workflows and models.
GR00T Reference Workflows
Open, validated sim and real workflows that unify every stage of the pipeline for faster end-to-end humanoid development.
GR00T Models
Open, general-purpose foundation models for humanoid reasoning and behavior, adaptable across embodiments and tasks through fine-tuning.
Video End-to-end Humanoid Robot Development
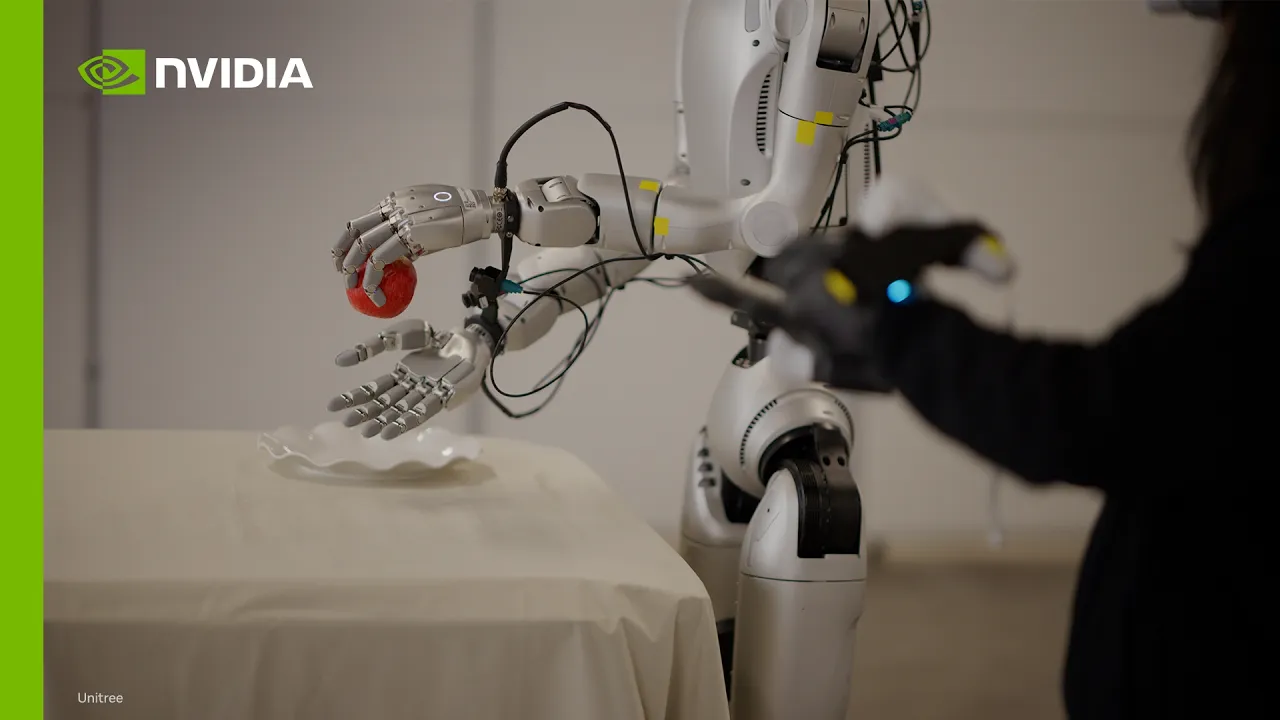
Learn how Isaac GR00T brings together the full development pipeline, helping developers move faster from data collection, to training and evaluating policies, to deploying on real robots.
Isaac GR00T Reference Platform
Build on an open, full-stack, NVIDIA-accelerated platform with simulation frameworks, data generation pipelines, training libraries, open models, and NVIDIA Jetson Thor onboard compute.
Isaac GR00T Reference Workflows
Follow a fully open, validated, and reproducible path from data collection and policy training to evaluation and deployment on physical robots. Use NVIDIA software, your own tools, or a combination of both.


Capture Data
Capture high-quality demonstrations through teleoperation in simulation or on a physical robot, then convert the data for GR00T post-training.

Train and Evaluate Policies
Post-train GR00T models with real or simulated demonstrations, then evaluate the policy in Isaac Lab-Arena before deployment.

Deploy on the Robot
Export the trained policy and deploy on Jetson Thor™ for real-time, on-device inference and control.
Isaac GR00T Family of Models
Start with pre-trained GR00T foundation models for generalized robot skills, then fine-tune and deploy them across embodiments and environments.

Get started with GR00T 1.7
GR00T 1.7 is the latest open VLA model in the GR00T family, with a Cosmos backend and commercial license. The 3-billion-parameter model is available on GitHub and Hugging Face.

Orchestrate with Frontier AI
Use frontier AI models like GPT-6 Astra to decompose complex goals into actionable steps, with GR00T translating those plans into robot actions.

Run GR00T 1.7 on Jetson Thor
Use the Jetson Thor deployment guide for Docker setup and accelerated GR00T 1.7 inference with TensorRT™ NVFP4 quantization at 25 Hz.

Use GR00T on LeRobot
GR00T 1.7 is available on LeRobot, streamlining model training, fine-tuning and deployment across a wide range of robots and tasks.
Ecosystem
Humanoid Robotics Ecosystem
NVIDIA builds platforms, foundation models, acceleration libraries, and blueprints to accelerate the world’s ecosystem of humanoid developers.


Explore the Latest Isaac GR00T Resources
-
Blogs
-
Sessions
-
Developer Stories
Next Steps
Ready to Build With Isaac GR00T?
Start with the latest open GR00T model, then adapt it to your robot, task, and environment.
Explore the Code
Access model code, fine-tuning scripts, inference examples, evaluation guidance, and community contributions.
Follow the End-to-End Workflow
Follow the complete, modular workflow from simulation setup and data creation through policy training, evaluation, and deployment readiness.
Frequently Asked Questions
NVIDIA Isaac GR00T is an open reference platform for general-purpose humanoid robots. It brings together open data and pipelines, robot foundation models, simulation frameworks, middleware, accelerated runtime libraries, and Jetson Thor for real-time inference and control.
GR00T models take onboard camera views, a natural-language instruction, and the robot’s current state as input. The policy predicts chunks of continuous robot actions, helping produce coordinated and smooth manipulation behavior.
GR00T models learn from a diverse mixture of internet-scale human video, real robot teleoperation data, and synthetic data generated in simulation. This mix provides world knowledge, physical grounding, and scalable task coverage.
Yes. Developers can post-train GR00T with a focused set of real or synthetic demonstrations for a specific embodiment, task, or environment while retaining broad capabilities learned during pretraining.
GR00T provides a repeatable path from data to deployment: Set up a simulation environment, capture demonstrations, train or post-train a policy, evaluate it in simulation, and deploy it for real-time inference and control with NVIDIA Jetson Thor.